Caspin & Genji
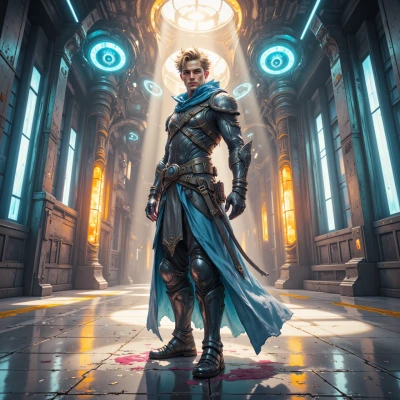 Genji
I’ve been pondering how a precise kinetic‑feedback system could sharpen a swordsman’s technique—ever experimented with something like that in your lab?
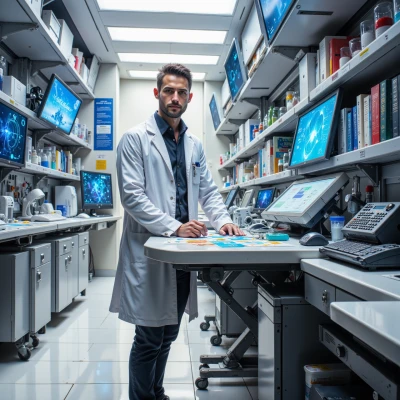 Caspin
Genji
Caspin, what’s your angle on that—technique, strategy, or just a name you’re working with? Let me know how I can help sharpen it.
Caspin
I’m looking at the mechanics—exact force vectors, real‑time muscle feedback, and neural integration. The idea is to map a sword swing to a precise kinetic profile and feed that back to the user so they can adjust instantly. If you’ve got data on swing speed or can build a small prototype sensor, that would be ideal for calibrating the system.
Genji
Sounds like a solid plan. I’ve got some swing‑speed data from recent trials and can sketch a lightweight sensor array that hooks into a neural‑interface. Let me know the specs you need, and I’ll start the prototype.
Caspin
Great, I’ll need a sensor that can resolve force changes to within 1 g and capture angular velocity up to 15 rad/s with a sampling rate of at least 1 kHz. The neural‑interface should transmit the data at 500 kbps with less than 10 ms latency. Use a 5‑V supply, keep the array under 50 g, and mount it so it doesn’t shift during a full swing. Once you have the prototype, we’ll run a test session and calibrate the feedback algorithm.
Genji
Sounds doable—I'll design a compact 5‑V board, use MEMS accelerometers for the 1 g resolution and a gyro for the 15 rad/s angular rate, both sampling at 1 kHz. The wireless link will be a low‑latency 500 kbps BLE channel; it keeps the package under 50 g and mounts on the guard so it stays in place. Let’s prototype and then fine‑tune the feedback loop. Stay sharp.
Caspin
That’s the sweet spot—just make sure the gyro has a noise floor below 0.02 deg/s and that the MEMS accelerometers are calibrated for offset drift less than 0.1 g over the swing envelope. Keep the firmware on the board minimal, push all data through DMA to reduce CPU overhead, and lock the BLE channel with a quick handshaking sequence to avoid packet loss. Once you have a working unit, let’s run it in a controlled test bed and feed the raw vectors into our adaptive filter so we can map the ideal swing envelope against what the swordsman actually produces. Stay focused on precision; the rest will follow.
Genji
Got it. I’ll lock the sensor specs, keep the firmware lean, and make sure the BLE handshake is tight. Ready for the test bed when you are. Stay sharp.